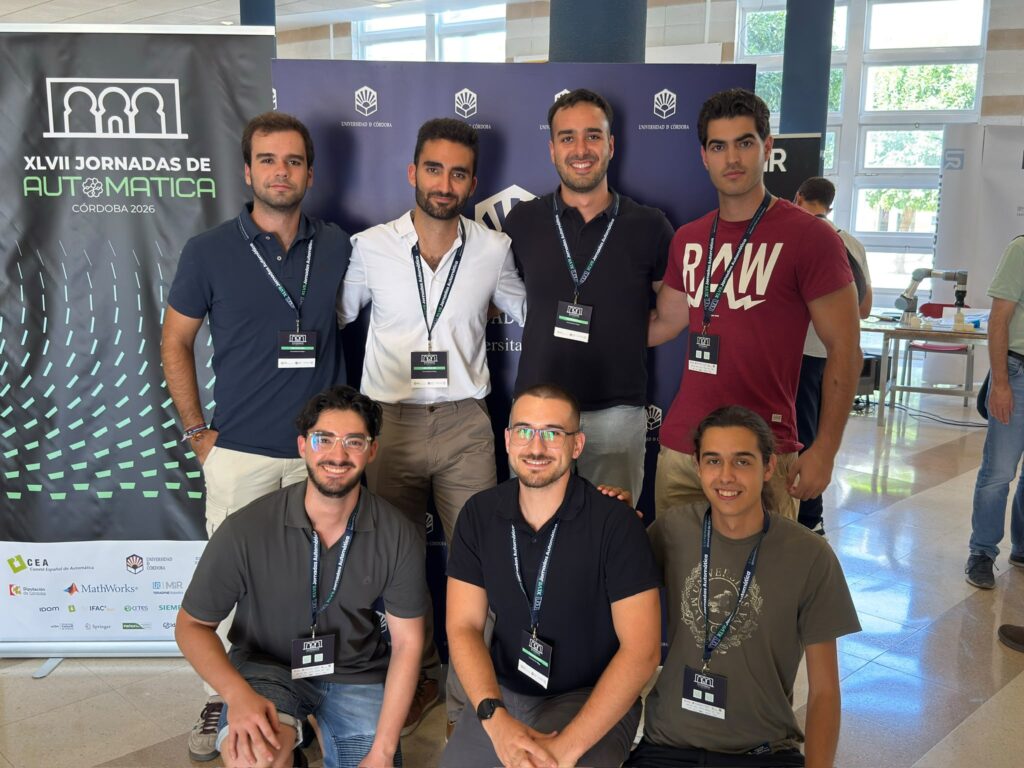
MAPIR at XLVII Jornadas de Automática in Córdoba
From September 2nd to 4th, the MAPIR group took part in the XLVII Jornadas de Automática in Córdoba, the annual meeting of the Spanish automatic control and robotics community organised by the Comité Español de Automática (CEA). Seven members of the group attended: Adrián Bañuls Arias, Antonio Cañete Baena, Pablo Hormigo Jiménez, Jesús Moncada Ramírez, Eulogio Quemada Torres, Jorge Serrano Mesa and Alejandro Valencia Rojas. Together we presented 5 contributions covering semantic mapping, human-robot interaction, decision making for service robots and reinforcement learning:
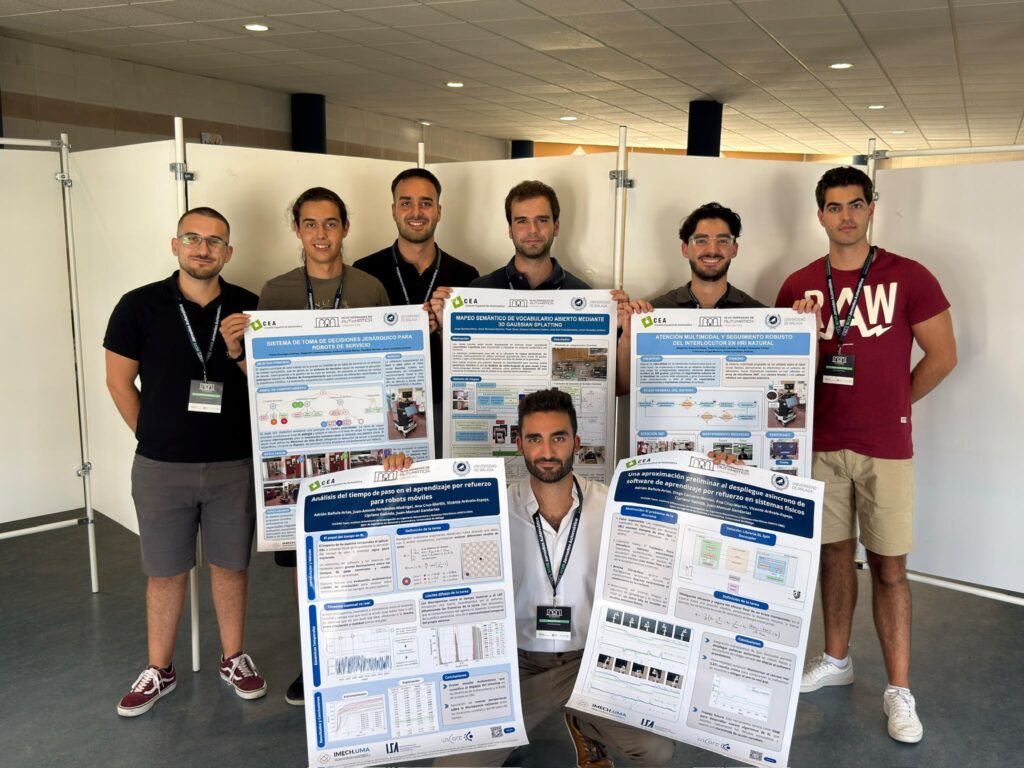
- Open-vocabulary semantic mapping with 3D Gaussian Splatting (Mapeo semántico de vocabulario abierto mediante 3D Gaussian Splatting): combines the geometric and photorealistic representation of Gaussian Splatting with open-vocabulary semantics, giving mobile robots richer maps of their environment.
- Multimodal attention for natural human-robot interaction (Atención multimodal y seguimiento robusto del interlocutor en HRI natural): an architecture that fuses audio and vision so that our robot Sancho can locate who is speaking, turn towards them, identify them and keep tracking them even when their face briefly leaves the camera view. It also integrates an LLM-based conversational agent and expressiveness mechanisms that adapt the robot’s responses during the conversation.
- Hierarchical decision making for service robots (Sistema de toma de decisiones jerárquico para robots de servicio): a Behavior Tree architecture for Sancho, implemented in ROS 2, that organises energy management, conversational interruptions, mission execution and idle routines into priority layers, so the robot can be interrupted by voice commands or go back to recharge without stopping its operation.
- Reinforcement learning on real robots: two papers, Una aproximación preliminar al despliegue asíncrono de software de aprendizaje por refuerzo en sistemas físicos and Análisis del tiempo de paso en el aprendizaje por refuerzo para robots móviles, developed with the UnCORE team (IMECH-UMA) within the TYRELL project, which studies the role of time in reinforcement learning for robotic skills and tasks.
Beyond the presentations, the Jornadas de Automática were a great chance to attend sessions from other thematic groups such as Computer Vision and Robotics, learn about the research of other Spanish groups, and come back with new contacts and ideas. For Antonio Cañete and Eulogio Quemada, this edition was also the prelude to the start of theirs PhDs. We thank the CEA for the organisation and everyone we met in Córdoba for the fruitful discussions. See you next year!