
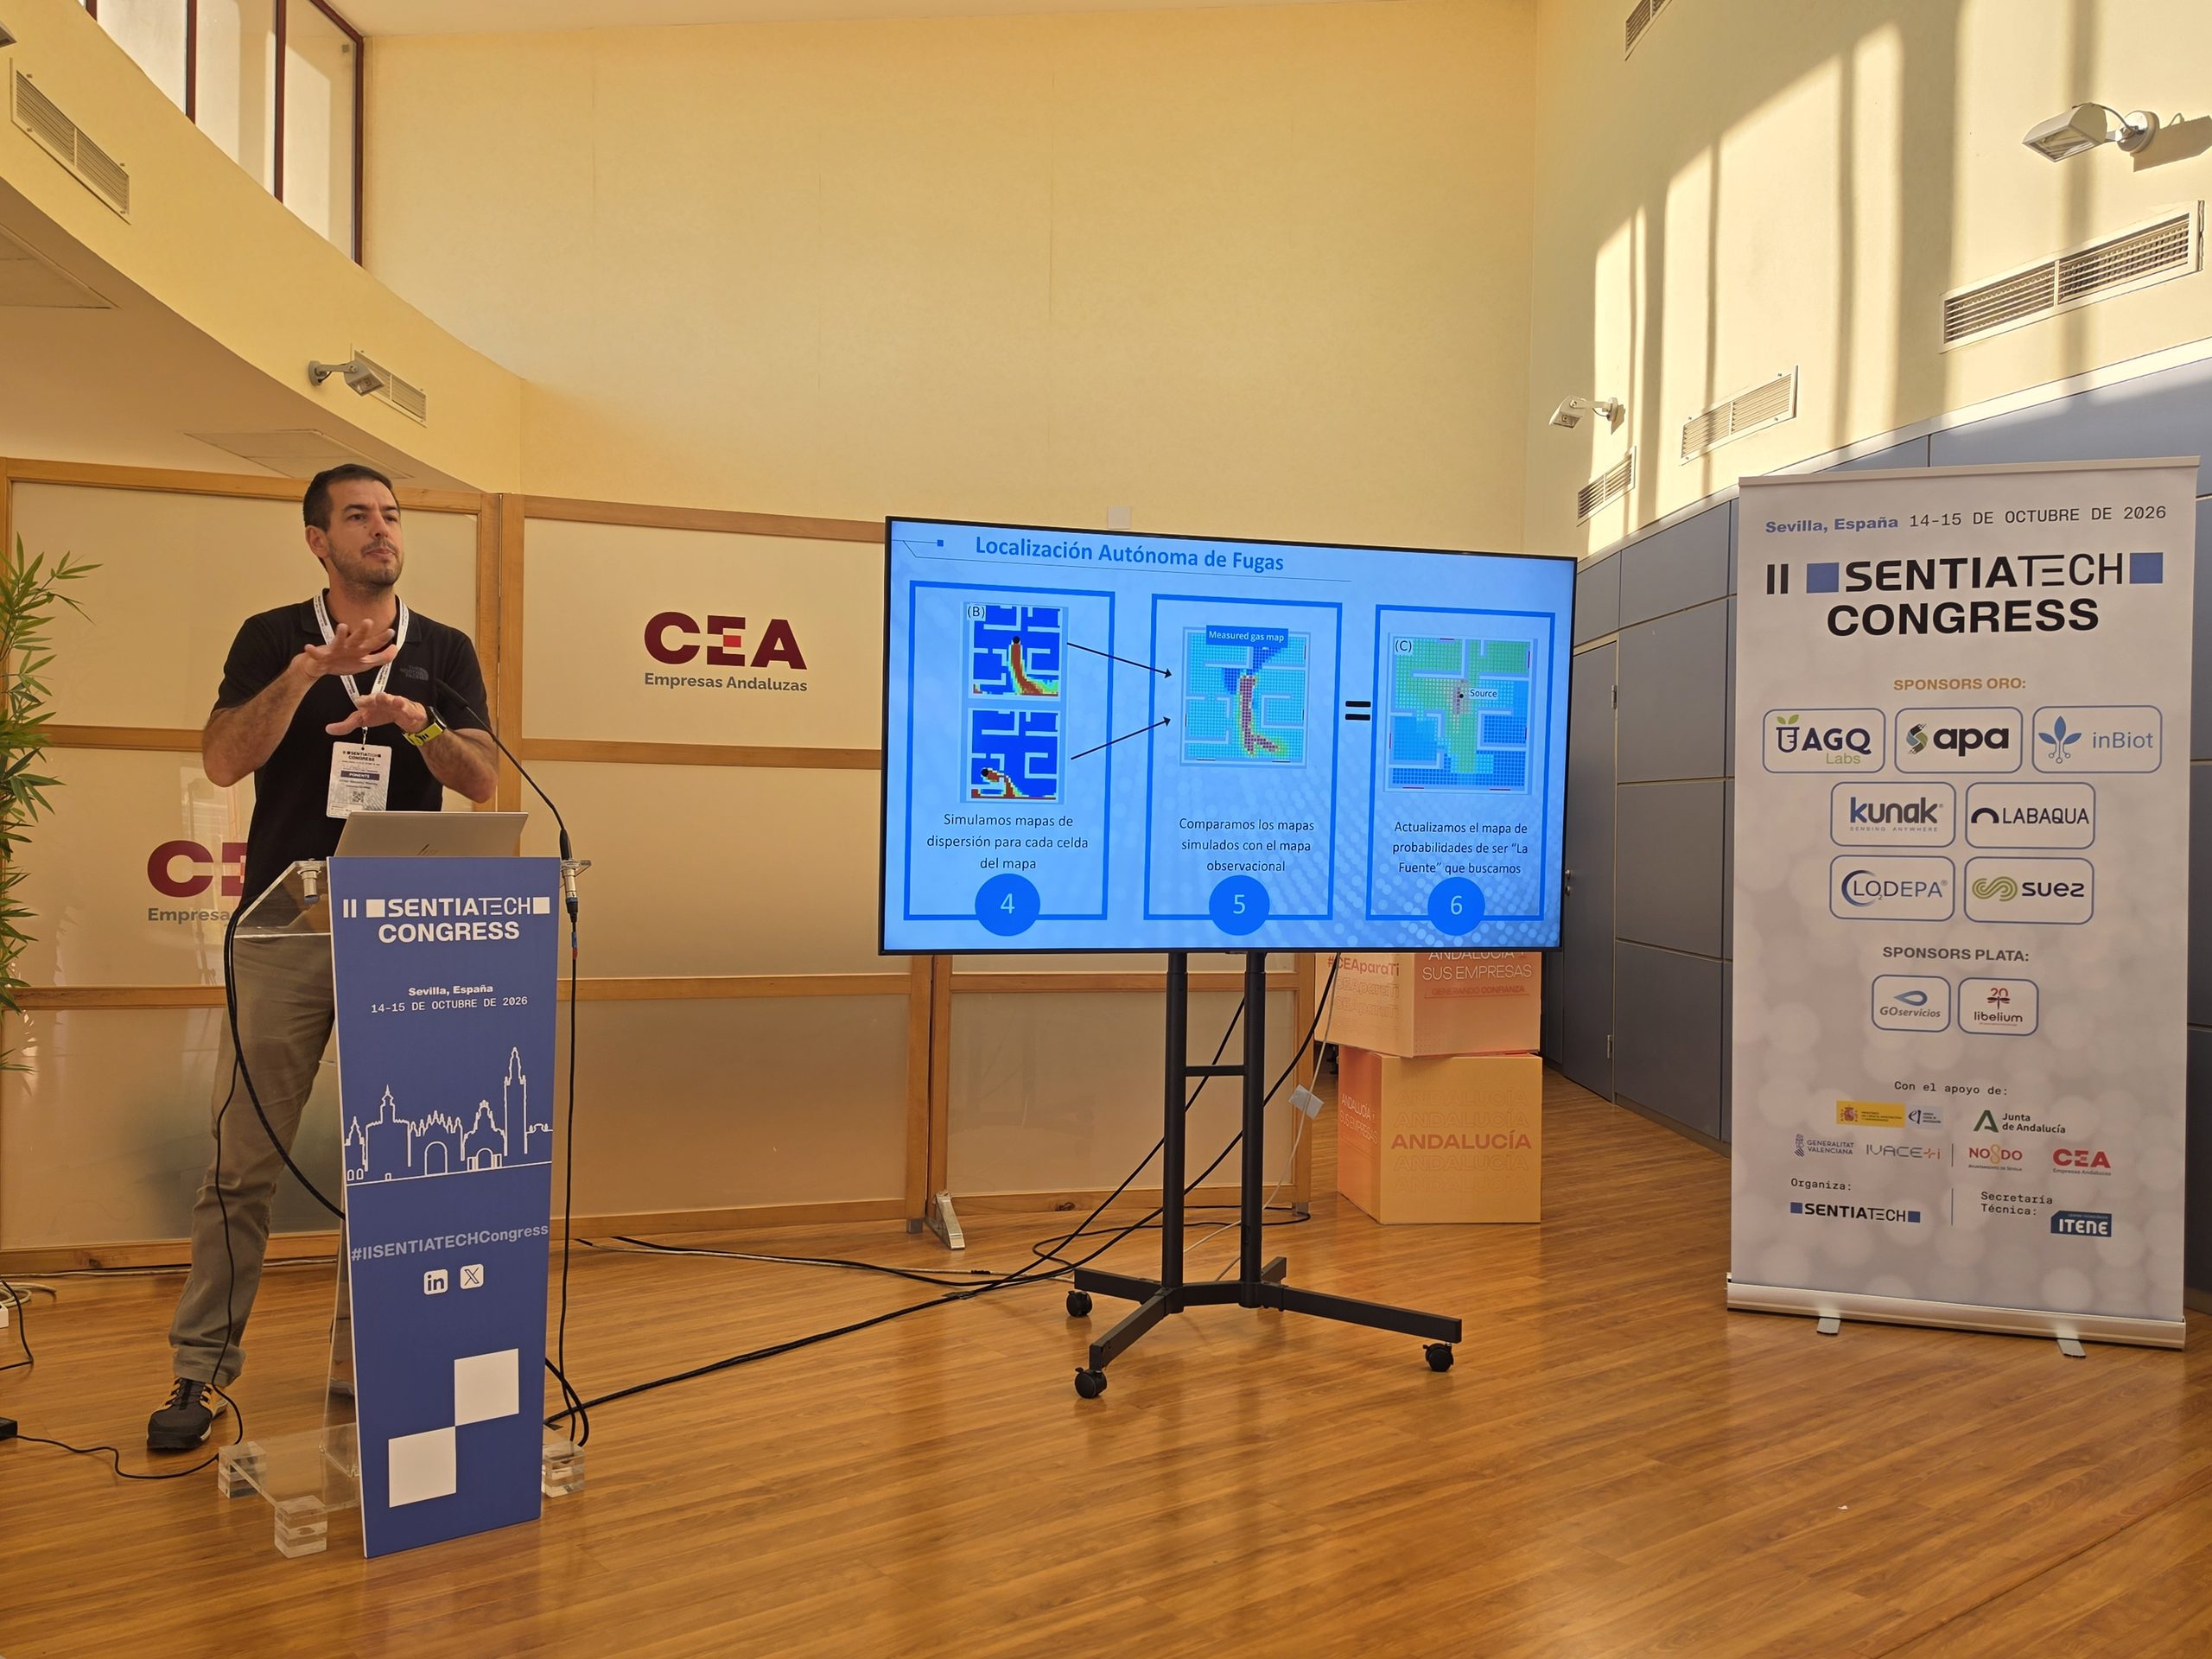
Airflow modeling and source localization at the II SENTIATECH Congress
On October 14–15, we attended the II SENTIATECH Congress in Seville, focused on “Prediction, Monitoring, and Management of Air Quality“. The conference theme closely aligns with our research line “robotics olfaction” at MAPIR, where we apply mobile robotics, artificial olfaction, and spatial perception to tackle real-world environmental health challenges. During the event, we delivered two oral presentations detailing how our sensing and probabilistic modeling tools contribute to air quality assessment:
- Airflow modeling with GMRF-W: We presented our hybrid approach that combines physical transport principles with Gaussian Markov Random Fields (GMRF-W). This methodology allows us to reconstruct continuous 2D ventilation and wind maps from sparse measurements (IoT sensor networks/ mobile robot) in real time, offering a lightweight alternative to traditional CFD simulations.
- Gas source localization strategies: We shared our ongoing research on locating emission sources and gas leaks using mobile robotics and environmental sensing, aiming to improve autonomous monitoring and safety.
It was a great opportunity to connect with researchers and professionals working on air quality management and to discuss future applications for our robotic and sensing frameworks.

