Member of the MAPIR and UnCORE research groups Dept. of Systems Engineering and Automation – University of Málaga
E-mail: adrianb_arias@uma.es Address: Escuela Técnica Superior de Ingeniería Informática. Bulevar Louis Pasteur 35. 29071 Málaga, Spain.
Contents
Short bio
Adrián Bañuls Arias received his Bachelor’s Degree in Robotics, Electronics and Mechatronics Engineering from the University of Málaga in 2019, graduating with honors and publishing a paper at the IEEE International Symposium on Safety, Security and Rescue Robotics (SSRR). He later earned two master’s degrees, one in Mechatronic Engineering and another in Artificial Intelligence. After completing his postgraduate studies, he spent several years in industry developing and integrating advanced robotic systems across various sectors, combining practical engineering expertise with cutting-edge AI methods. In 2025 he began his Ph.D. in Mechatronic Engineering at the University of Málaga, where his research focuses on Reinforcement Learning and its applications to robotics.
Research
Research interests
Reinforcement Learning for robotics
Control of Robotic Manipulators
Mobile robot navigation
PhD Thesis
Title: Action Time in Reinforcement Learning for Robotics Programme: PhD Programme in Mechatronic Engineering, University of Málaga Supervisors: Juan Antonio Fernández Madrigal and Vicente Arévalo Espejo Start: February 2025
Abstract. Reinforcement Learning (RL) has shown great potential in robotics over the past decade. However, one fundamental aspect remains largely overlooked: time. RL has traditionally been applied to turn-based games such as chess, where the problem reduces to a discrete sequence of moves, and time plays no role. In robotics, by contrast, time emerges in many ways, including the optimal duration of each action, the range of durations allowed by the operating frequencies of actuators and sensors, and the gap between nominal and effective action times caused by latencies, communication delays or computational load. This thesis studies how these temporal factors affect the performance of RL algorithms and how to adapt these algorithms accordingly.
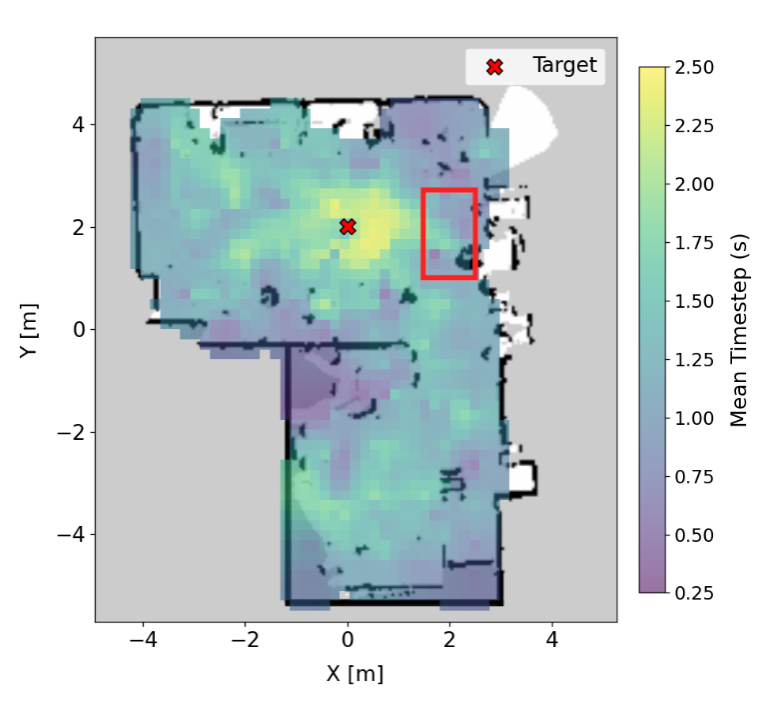
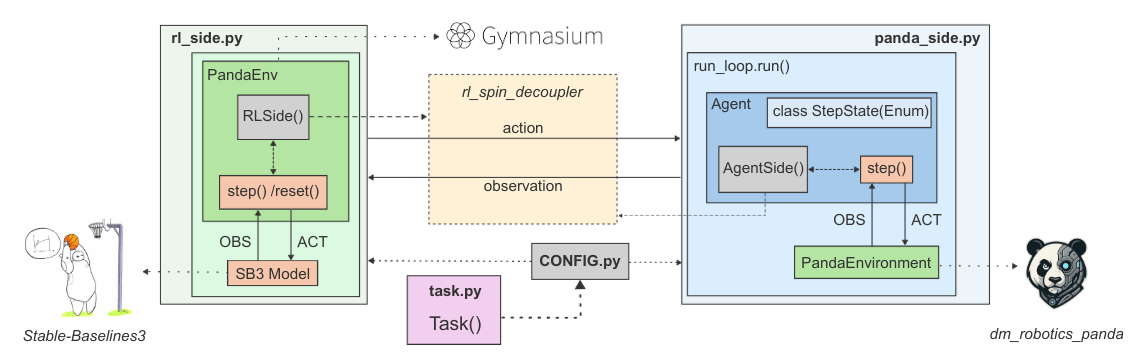
The main contributions to date are as follows. First, a software library has been developed to decouple the agent from the learning algorithm, enabling a more reliable study of time. Second, an exhaustive multi-metric analysis has been conducted to determine the optimal action time for a robotic navigation task. Third, the robot has been given the ability to learn and select its own action time, which has led to a tool for building safety maps of its environment. Ongoing work extends this research to further temporal factors.
Publications
Journals (2)
2026
A. Bañuls-Arias, C. Galindo, A. Cruz-Martín, M. Castellano Quero, J.M. Gandarias-Palacios, J.A. Fernández-Madrigal, V. Arevalo-Espejo
@article{banulsarias2026,
title = {Modeling Time-Aware Mobile Robot Navigation by Learning Subjective Time Maps (STM)},
author = {Bañuls-Arias, Adrián and Galindo, Cipriano and Cruz-Martín, Ana and Castellano Quero, Manuel and Gandarias-Palacios, Juan-Manuel and Fernández-Madrigal, Juan-Antonio and Arevalo-Espejo, Vicente},
url = {https://doi.org/10.32604/cmes.2026.085976},
doi = {10.32604/cmes.2026.085976},
issn = {1526-1506},
year  = {2026},
date = {2026-07-01},
urldate = {2026-07-01},
journal = {Computer Modeling in Engineering & Sciences},
volume = {148},
number = {1},
pages = {33},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
@article{fernandez2025gof,
title = {Goodness of Fit in the Marginal Modeling of Round-Trip Times for Networked Robot Sensor Transmissions},
author = {Fernández-Madrigal, Juan-Antonio and Arevalo-Espejo, Vicente and Cruz-Martín, Ana and Galindo, Cipriano and Bañuls-Arias, Adrián and Gandarias-Palacios, Juan-Manuel},
url = {https://www.mdpi.com/1424-8220/25/17/5413},
doi = {10.3390/s25175413},
issn = {1424-8220},
year  = {2025},
date = {2025-09-01},
journal = {MDPI Sensors},
volume = {25},
number = {17},
pages = {5413},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
2020 IEEE International Symposium on Safety, Security, and Rescue Robotics (SSRR), pp. 380-386, IEEE, Abu Dhabi, United Arab Emirates, 2020, ISBN: 978-1-6654-0390-0.
@inproceedings{Bañuls-Arias2020,
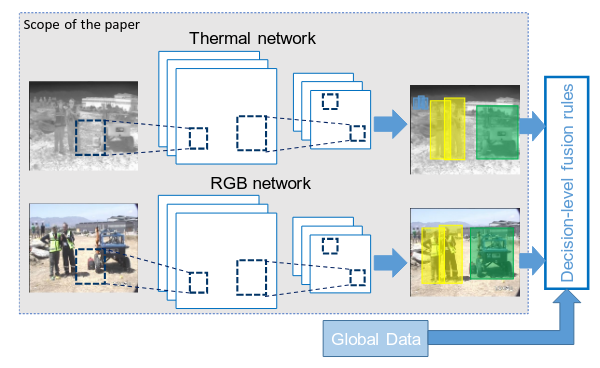
title = {Object Detection from Thermal Infrared and Visible Light Cameras in Search and Rescue Scenes},
author = {Bañuls-Arias, Adrián and Mandow, Anthony and Vazquez-Martin, Ricardo and Morales, Jesús and García-Cerezo, Alfonso},
url = {https://ieeexplore.ieee.org/document/9292593},
doi = {10.1109/SSRR50563.2020.9292593},
isbn = {978-1-6654-0390-0},
year  = {2020},
date = {2020-11-04},
urldate = {2020-11-04},
booktitle = {2020 IEEE International Symposium on Safety, Security, and Rescue Robotics (SSRR)},
pages = {380-386},
publisher = {IEEE},
address = {Abu Dhabi, United Arab Emirates},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
@inproceedings{banulsarias2026c,
title = {Análisis del tiempo de paso en el aprendizaje por refuerzo para robots móviles},
author = {Bañuls-Arias, Adrián and Fernández-Madrigal, Juan-Antonio and Cruz-Martín, Ana and Arevalo-Espejo, Vicente and Galindo, Cipriano and Gandarias-Palacios, Juan-Manuel},
url = {https://revistas.udc.es/index.php/JA_CEA/article/view/13780},
doi = {10.17979/ja-cea.2026.47.13780 },
year  = {2026},
date = {2026-06-01},
urldate = {2026-06-01},
booktitle = {Actas de las XLVII Jornadas de Automática},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
@inproceedings{banulsarias2026b,
title = {Una aproximación preliminar al despliegue ası́ncrono de software de aprendizaje por refuerzo en sistemas fı́sicos},
author = {Bañuls-Arias, Adrián and Caruana Montes, Diego and Cruz-Martín, Ana and Arevalo-Espejo, Vicente and Galindo, Cipriano and Gandarias-Palacios, Juan-Manuel},
url = {https://revistas.udc.gal/index.php/JA_CEA/article/view/13751},
doi = {10.17979/ja-cea.2026.47.13751 },
year  = {2026},
date = {2026-06-01},
urldate = {2026-06-01},
booktitle = {Actas de las XLVII Jornadas de Automática},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}