Dr. Mercedes García Salguero

Former member

I am Mercedes García Salguero, PhD Student associated with the Machine Perception and Intelligent Robotics group (MAPIR), department of Systems Engineering and Automation (ISA), at the University of Málaga (Spain).

E-mail: mercedesgarsal [at] uma.es
Main research interests:
Computer vision; global optimization

Address: Dpto. Ingenieria de Sistemas y Automatica, E.T.S.I. Informatica – Telecomunicacion, Universidad de Malaga, Campus Universitario de Teatinos, 29071 Malaga, Spain

github_logo

Short bio

I was born in Burgos, Spain. I received the B.Sc in “Grado en Ingeniería Electrónica, Robótica y Mecatrónica” (Degree in Electronics, Robotics and Mechatronics) from the University of Málaga in 2018 and the M.Sc in “Mecatrónica” (Mechatronics) in 2019. I am currently pursuing my PhD in “Mecatrónica” under the supervision of Prof. Javier Gonzalez-Jimenez


Topics

Here you can find a list of the topics covered during my thesis and the links to the published articles and available code.

Relative Pose Problem between calibrated cameras

See contributions
  • Certifiable relative pose estimation
    We provide an efficient optimality certifier for this problem. Paper. Code
  • Fast and Robust Certifiable Estimation of the Relative Pose Between Two Calibrated Cameras
    We contribute a fast and efficient certifiable solver and integrate a robust paradigm to detect and discard outliers. Paper. Code
  • A Sufficient Condition of Optimality for the Relative Pose Problem between Cameras
    We provide a sufficient optimality condition that assures the given solution is optimal without computing the full certifier. Paper. Code
  • A Tighter Relaxation for the Relative Pose Problem Between Cameras
    We contribute a set of convex relaxations that estimate the solution even for highly noisy data in less than 7 milliseconds Paper. Code

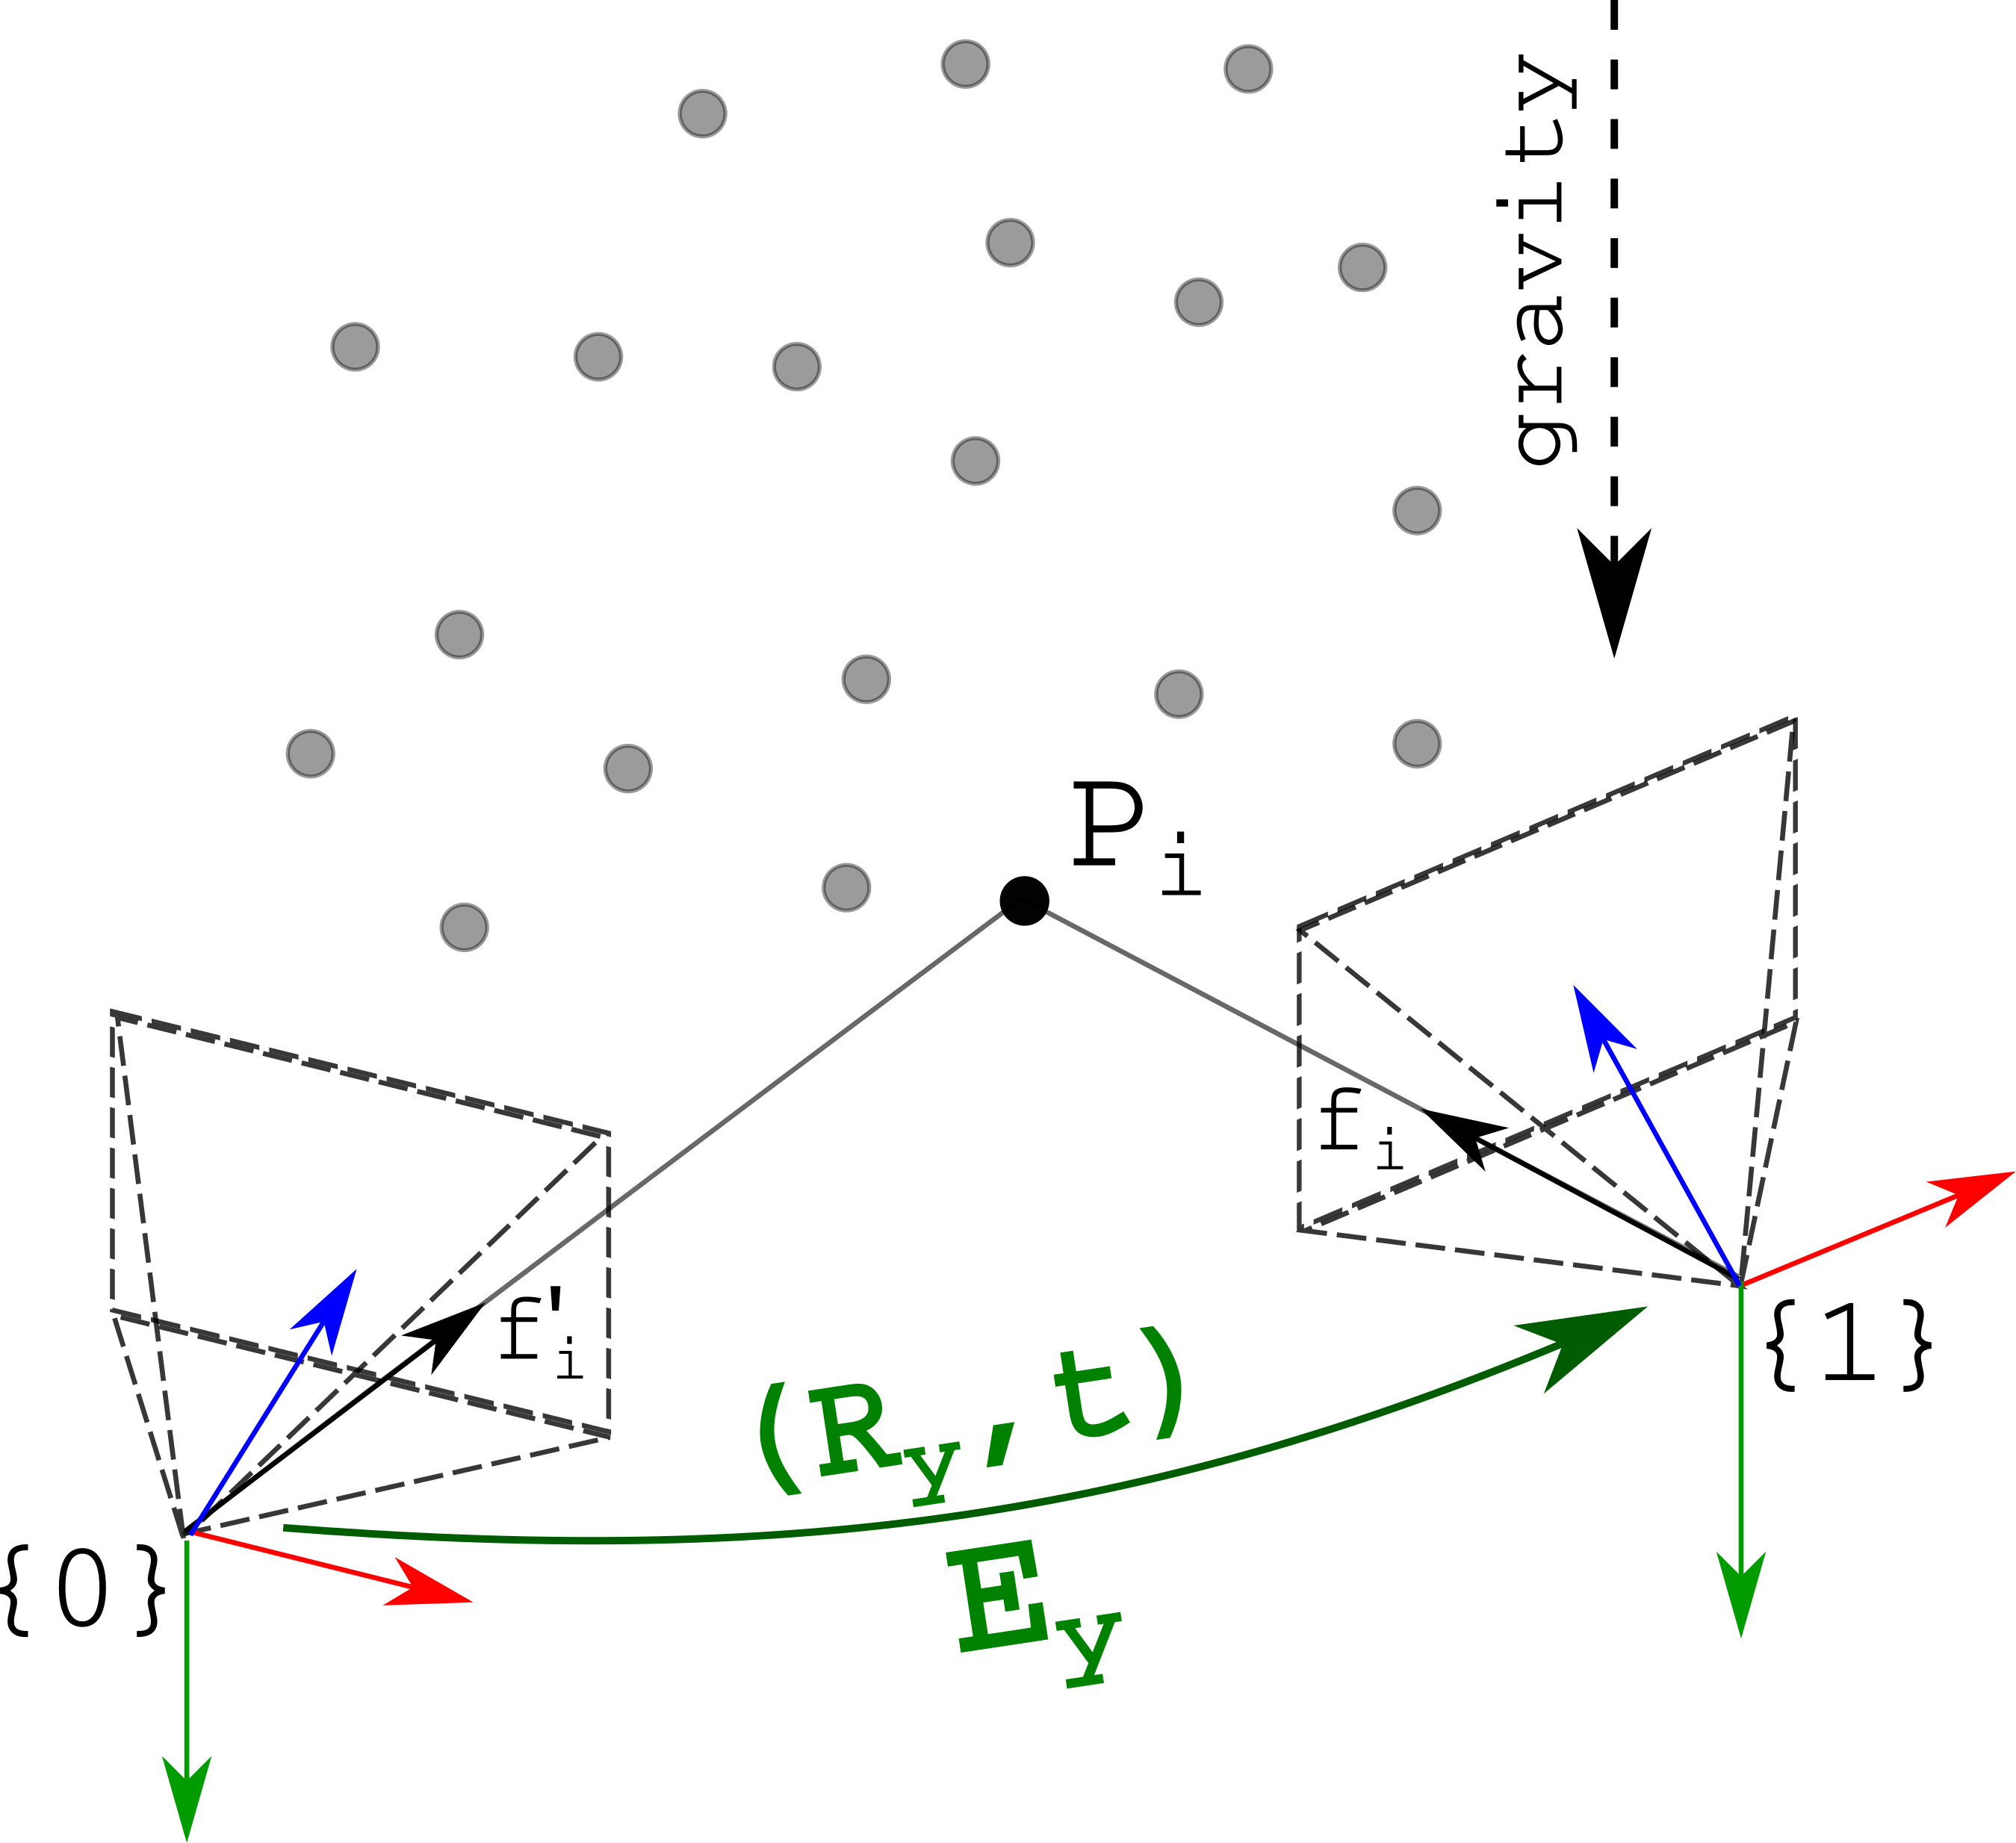
Relative pose problem with known information
See contributions

  • Fast certifiable relative pose estimation with gravity prior
    We provide an efficient optimality certifier for this problem under four different formulations.
    Code Generic certifier  Paper


Triangulation

See contributions
  • N-view triangulation
    We provide an efficient certifiable solver for this problem. Paper Code
  • Planar 2-view triangulation
    We propose three certifiable algorithms for the planar 2-view triangulation problem where the unknown 3D point is known to belong to a given plane Paper Code

Publications

Here you can find a list of my publications:


Journals (10)

2024

M. Garcia-Salguero, J. Gonzalez-Jimenez

Certifiable Planar Relative Pose Estimation with Gravity Prior

Computer Vision and Image Understanding, vol. 239, pp. 103887, 2024. Q2 · T2

M. Garcia-Salguero, E. Dima, A. Mateus, J. Gonzalez-Jimenez

Fast certifiable algorithm for the absolute pose estimation of a camera

SIAM Journal on Imaging Sciences, 2024.

2023

M. Garcia-Salguero, J. Gonzalez-Jimenez

Certifiable solver for real-time N-view triangulation

IEEE Robotics and Automation Letters, vol. 8, no. 4, pp. 1999-2005, 2023, ISSN: 2377-3766. Q2 · T1

M. Garcia-Salguero, J. Gonzalez-Jimenez

Fast certifiable relative pose estimation with gravity prior

Artificial Intelligence, 2023. Q1 · T1

2022

M. Garcia-Salguero, J. Gonzalez-Jimenez

Certifiable algorithms for the two-view planar triangulation problem

Computer Vision and Image Understanding, 2022. Q2 · T2

M. Garcia-Salguero, J. Briales, J. Gonzalez-Jimenez

A Tighter Relaxation for the Relative Pose Problem Between Cameras

Journal of Mathematical Imaging and Vision, no. 64, pp. 493-505, 2022. Q2 · T2

2021

M. Garcia-Salguero, J. Gonzalez-Jimenez

Fast and Robust Certifiable Estimation of the Relative Pose Between Two Calibrated Cameras

Journal of Mathematical Imaging and Vision, vol. 63, pp. 1036-1056, 2021. Q2 · T2

M. Garcia-Salguero, J. Briales, J. Gonzalez-Jimenez

Certifiable relative pose estimation

Image and Vision Computing, no. 63, 2021, ISSN: 0262-8856. Q1 · T1

M. Garcia-Salguero, J. Gonzalez-Jimenez

A Sufficient Condition of Optimality for the Relative Pose Problem between Cameras

SIAM Journal on Imaging Sciences, vol. 14, no. 4, pp. 1617–1634, 2021. Q2 · T1

2019

M. Garcia-Salguero, J. Gonzalez-Jimenez, F.A. Moreno

Human 3D Pose Estimation with a Tilting Camera for Social Mobile Robot Interaction

Sensors, vol. 19, no. 22: 4943, 2019. Q1 · T1

Conferences (2)

2019

M. Garcia-Salguero, J. Monroy, C. Galindo, J. Gonzalez-Jimenez

Extending an Assistance Robot with the Ability to Play Board Games

International Conference on Applications of Intelligent Systems (APPIS), Las Palmas de Gran Canaria (Spain), 2019.

M. Garcia-Salguero, J. Monroy, A. Solano, J. Gonzalez-Jimenez

Socially Acceptable Approach to Humans by a Mobile Robot

International Conference on Applications of Intelligent Systems (APPIS), Las Palmas de Gran Canaria (Spain), 2019.

National conferences (1)

2018

M. Garcia-Salguero, J. Monroy, J. Gonzalez-Jimenez

¿Jugamos? Mejora de la Interacción Humano-Robot Mediante Juegos de Mesa

XXXIX Jornadas de Automática, Badajoz (Spain), 2018, ISBN: 978-84-09-04460-3.

PhD Theses (1)

2024

M. Garcia-Salguero, J. Gonzalez-Jimenez

Certifiable Algorithms for 3D Computer Vision Problems

University of Málaga, 2024.


Similar Posts